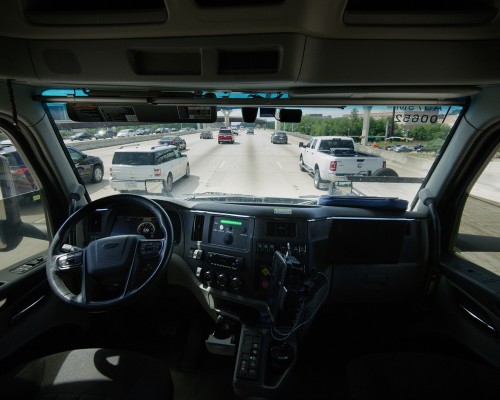
StatusEmpty cab, approved conditions; stops for people
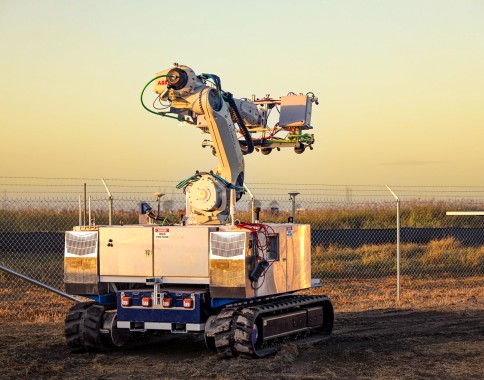
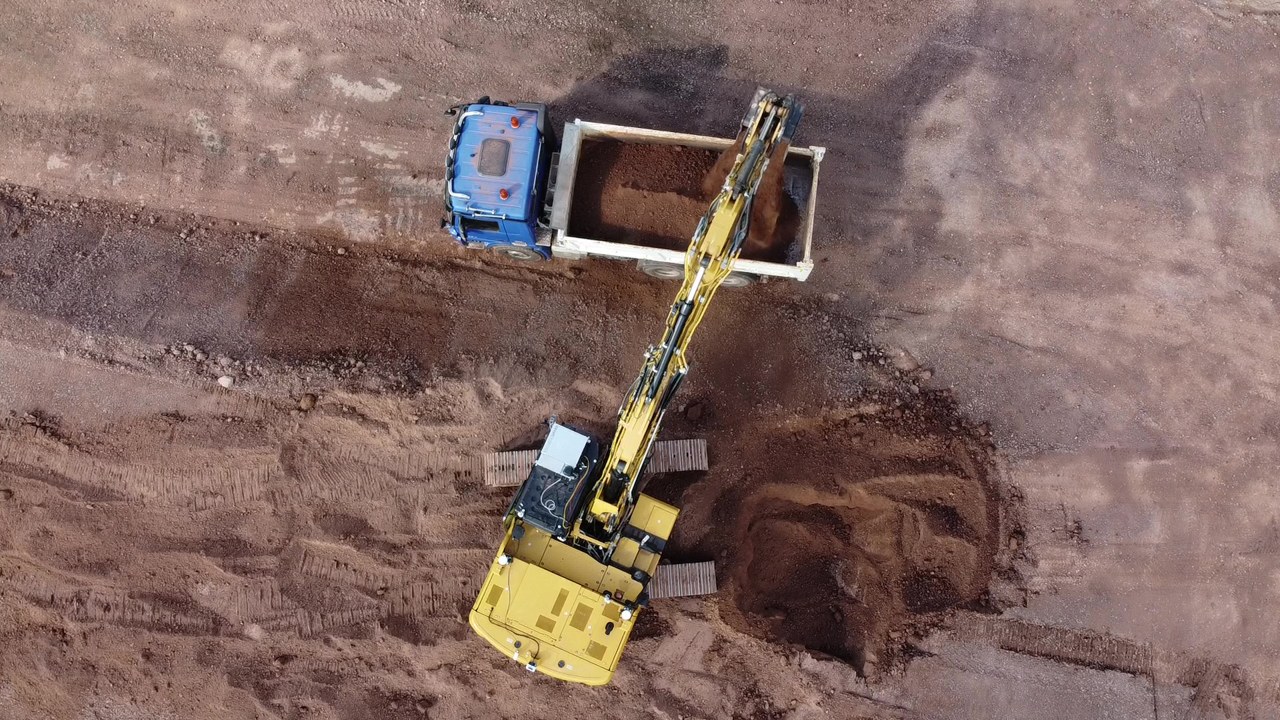
Gravis Robotics
TaskTrenching, earthmoving, truck loading
SiteManchester Airport, Holcim quarry
StatusAssist to remote; one person, many machines
Start with limited tasks, then widen the scope through expert know-how and field validation
14
14. The Evolution of KIMM's Robotics Research
Machine intelligence expanding into humanoid, field, and medical robots
Humanoids
Work in human environments
Field robots
Work at industrial and disaster sites
Medical robots
Precise medical tasks
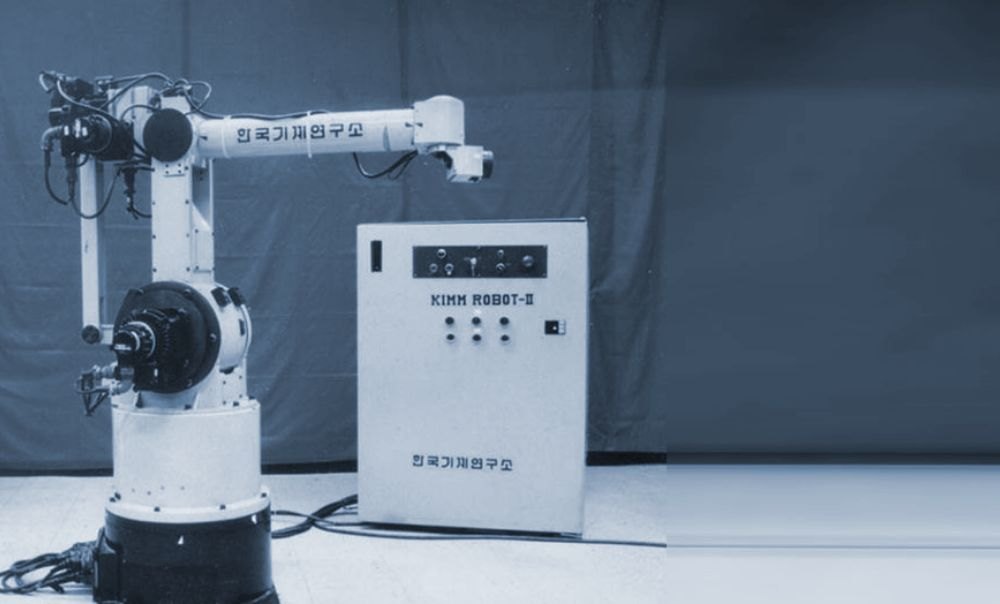
1986 Korea's first 6-axis industrial robot
▶
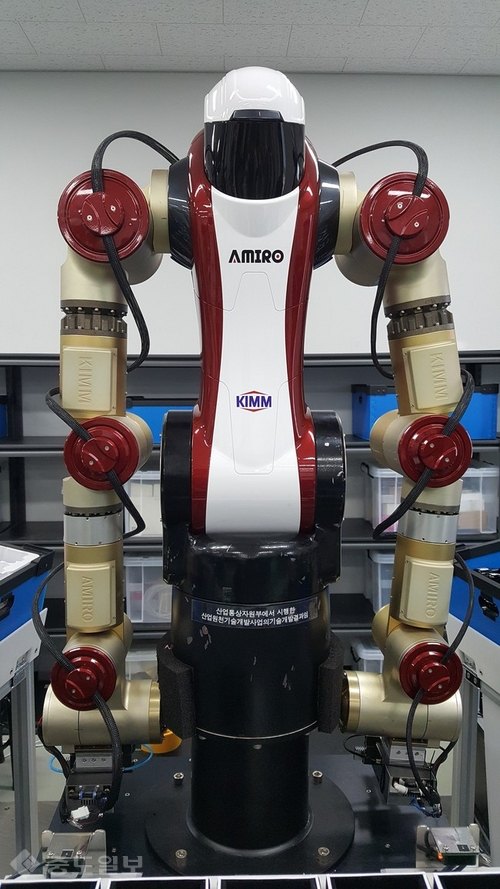
2010 Dual-arm robot AMIRO
▶
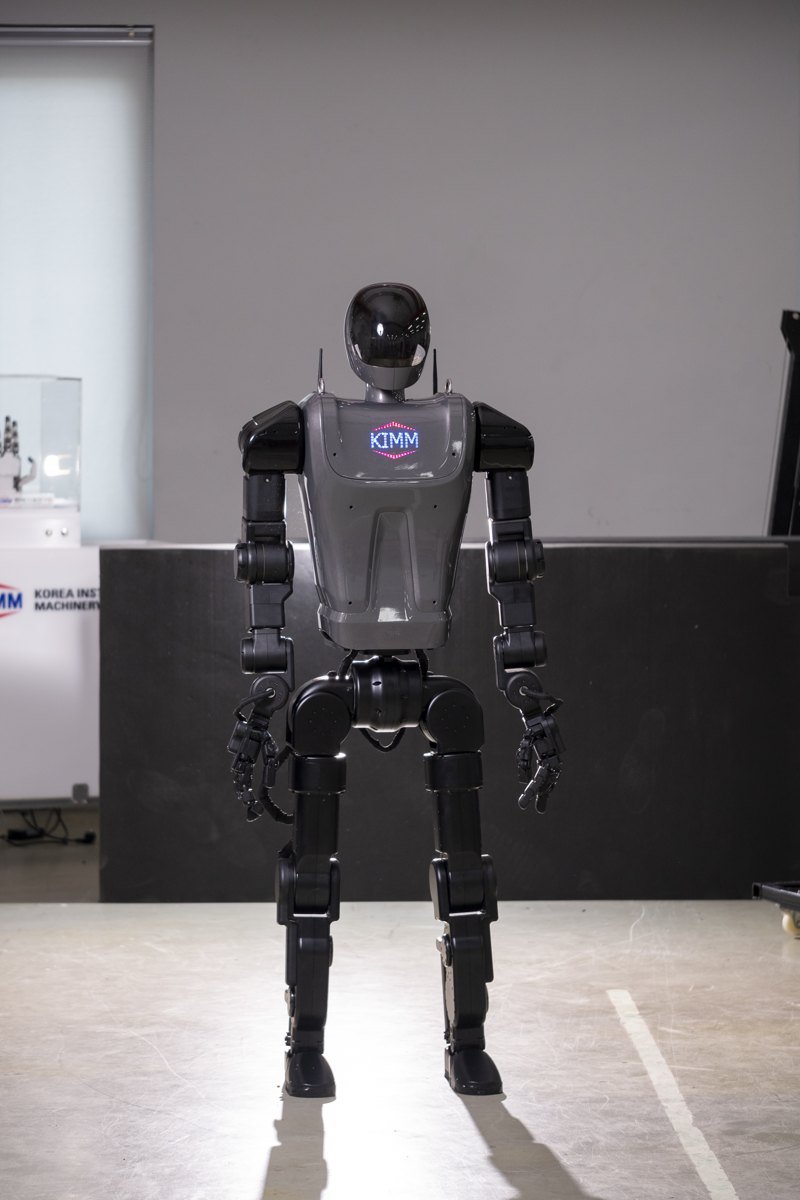
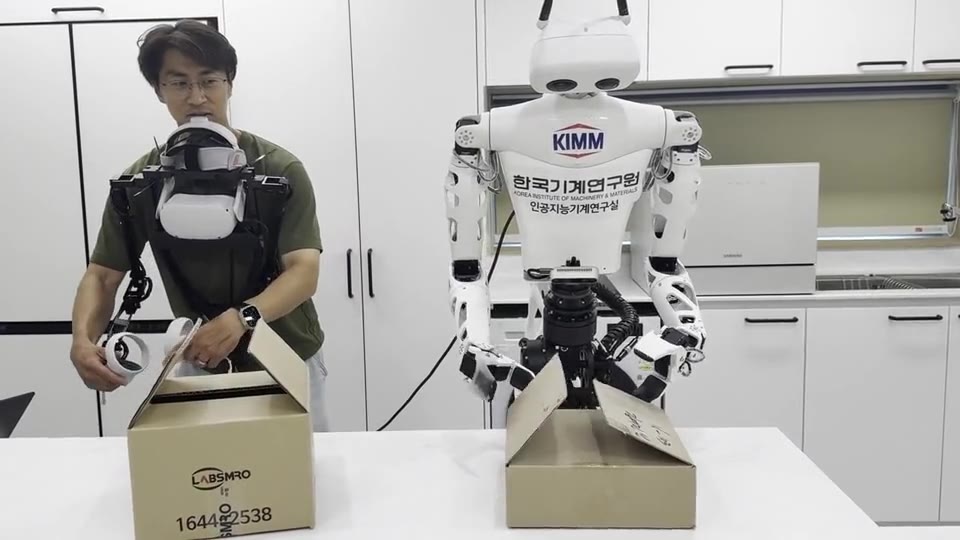
Now Humanoid KAIROS V0.7
15
15. Humanoid KAIROS
Developing robot platforms and core components for mobility and manipulation
2026 Global Mechanical Technology Forum Sep. 7, 2026
KAIROS V0.7 mask-dance demo
Roadmap2027.4V1▶2030.4V2 whole-body sensing▶2035Practical use
Actuator
2.1 kg, up to 192 N·m
5 in-house actuator types, 20% higher performance
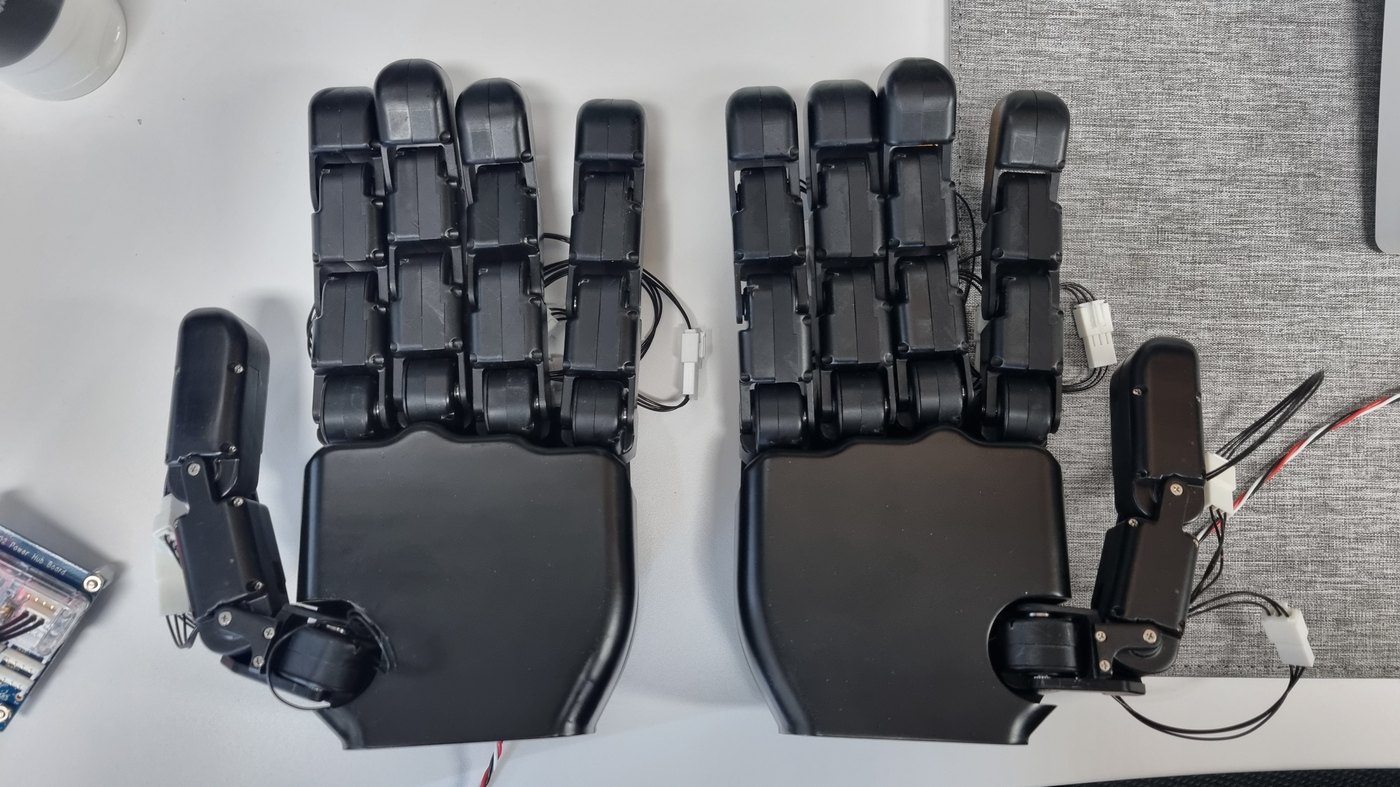
Robot hand
Holds tweezers for tiny parts
Built on years of hand research
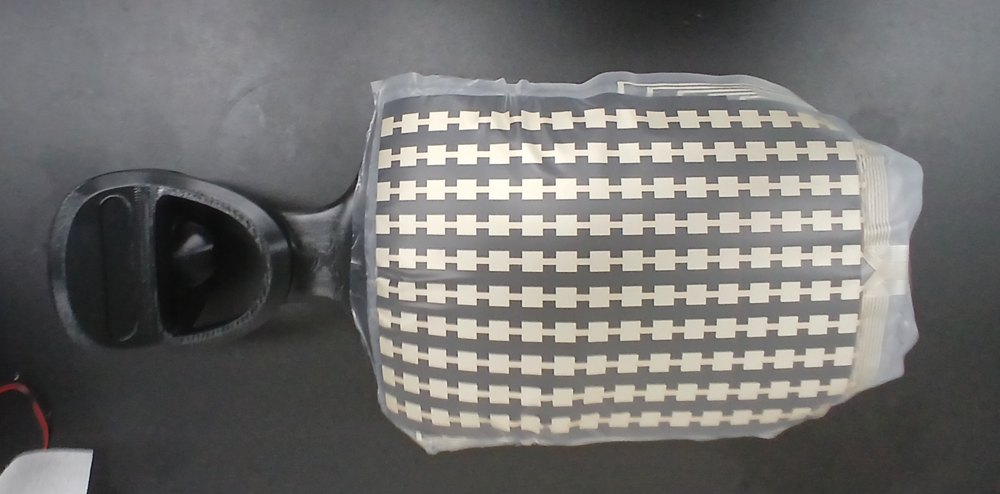
Tactile skin Unique
Senses even a gentle stroke
3-axis touch, self-healing skin
16
16. Robot Task Intelligence and Training Data
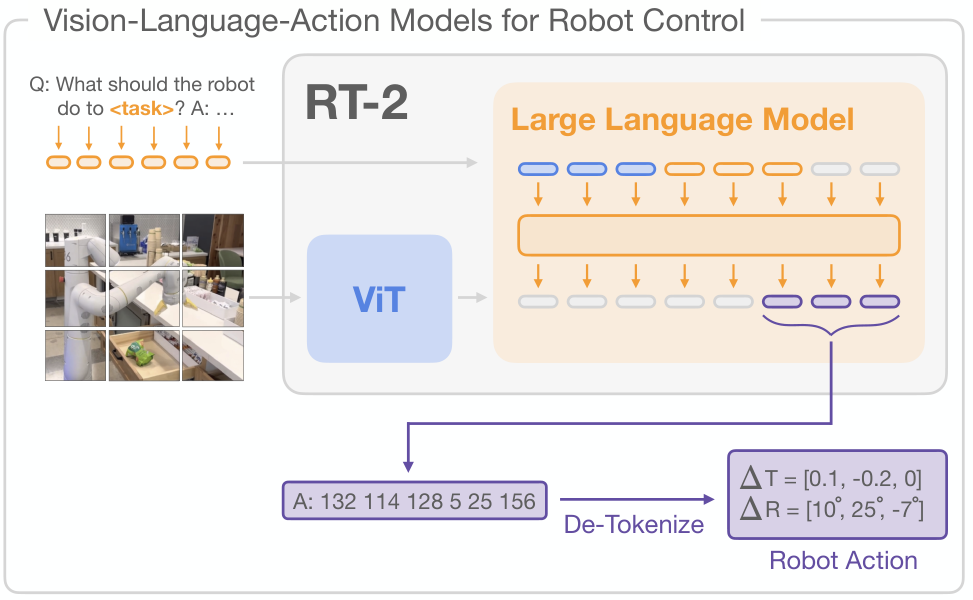
Learning from human demonstrations to scale to diverse tasks
1Collect demos
2Plan
3Execute tasks RoGeTA
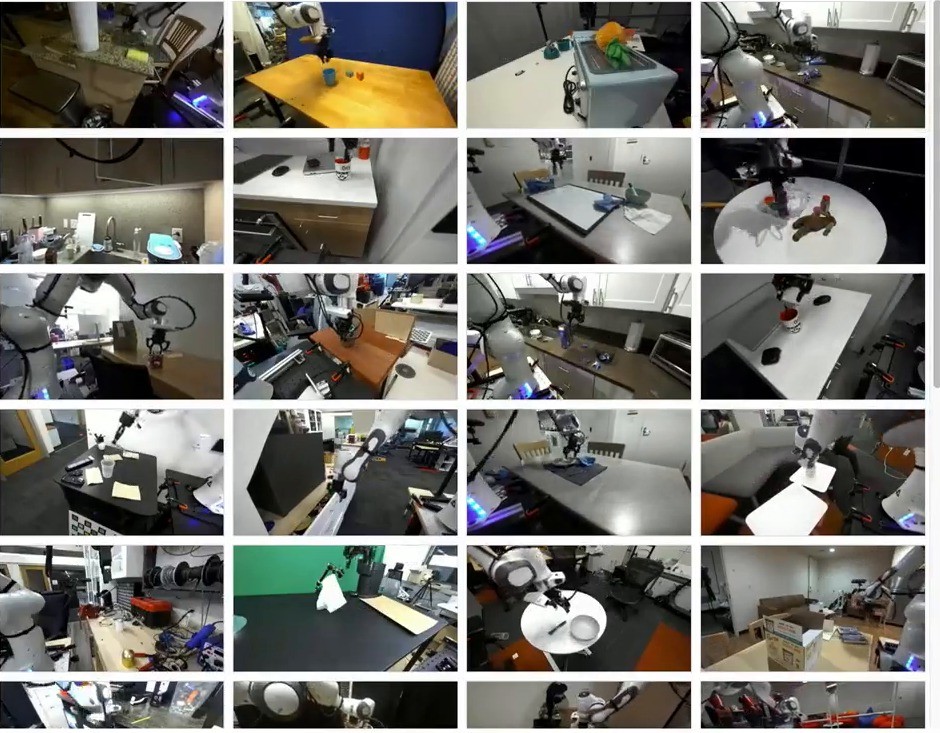
RoGeTA teaching device collects human demos
Data factory Collecting demos from many humanoids at once
▶
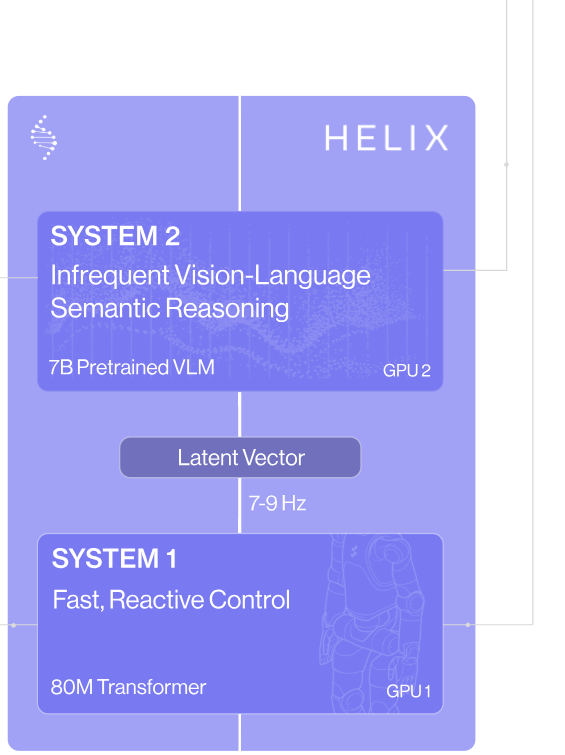
Command understandingLanguage-vision model
Task planningSequencing and checks
Skill compositionPick, place, recover
▶
Table tidying
Recycling sorting and handover
17
17. Autonomous Field Robot Work
Automating construction and agricultural tasks that require skilled operators
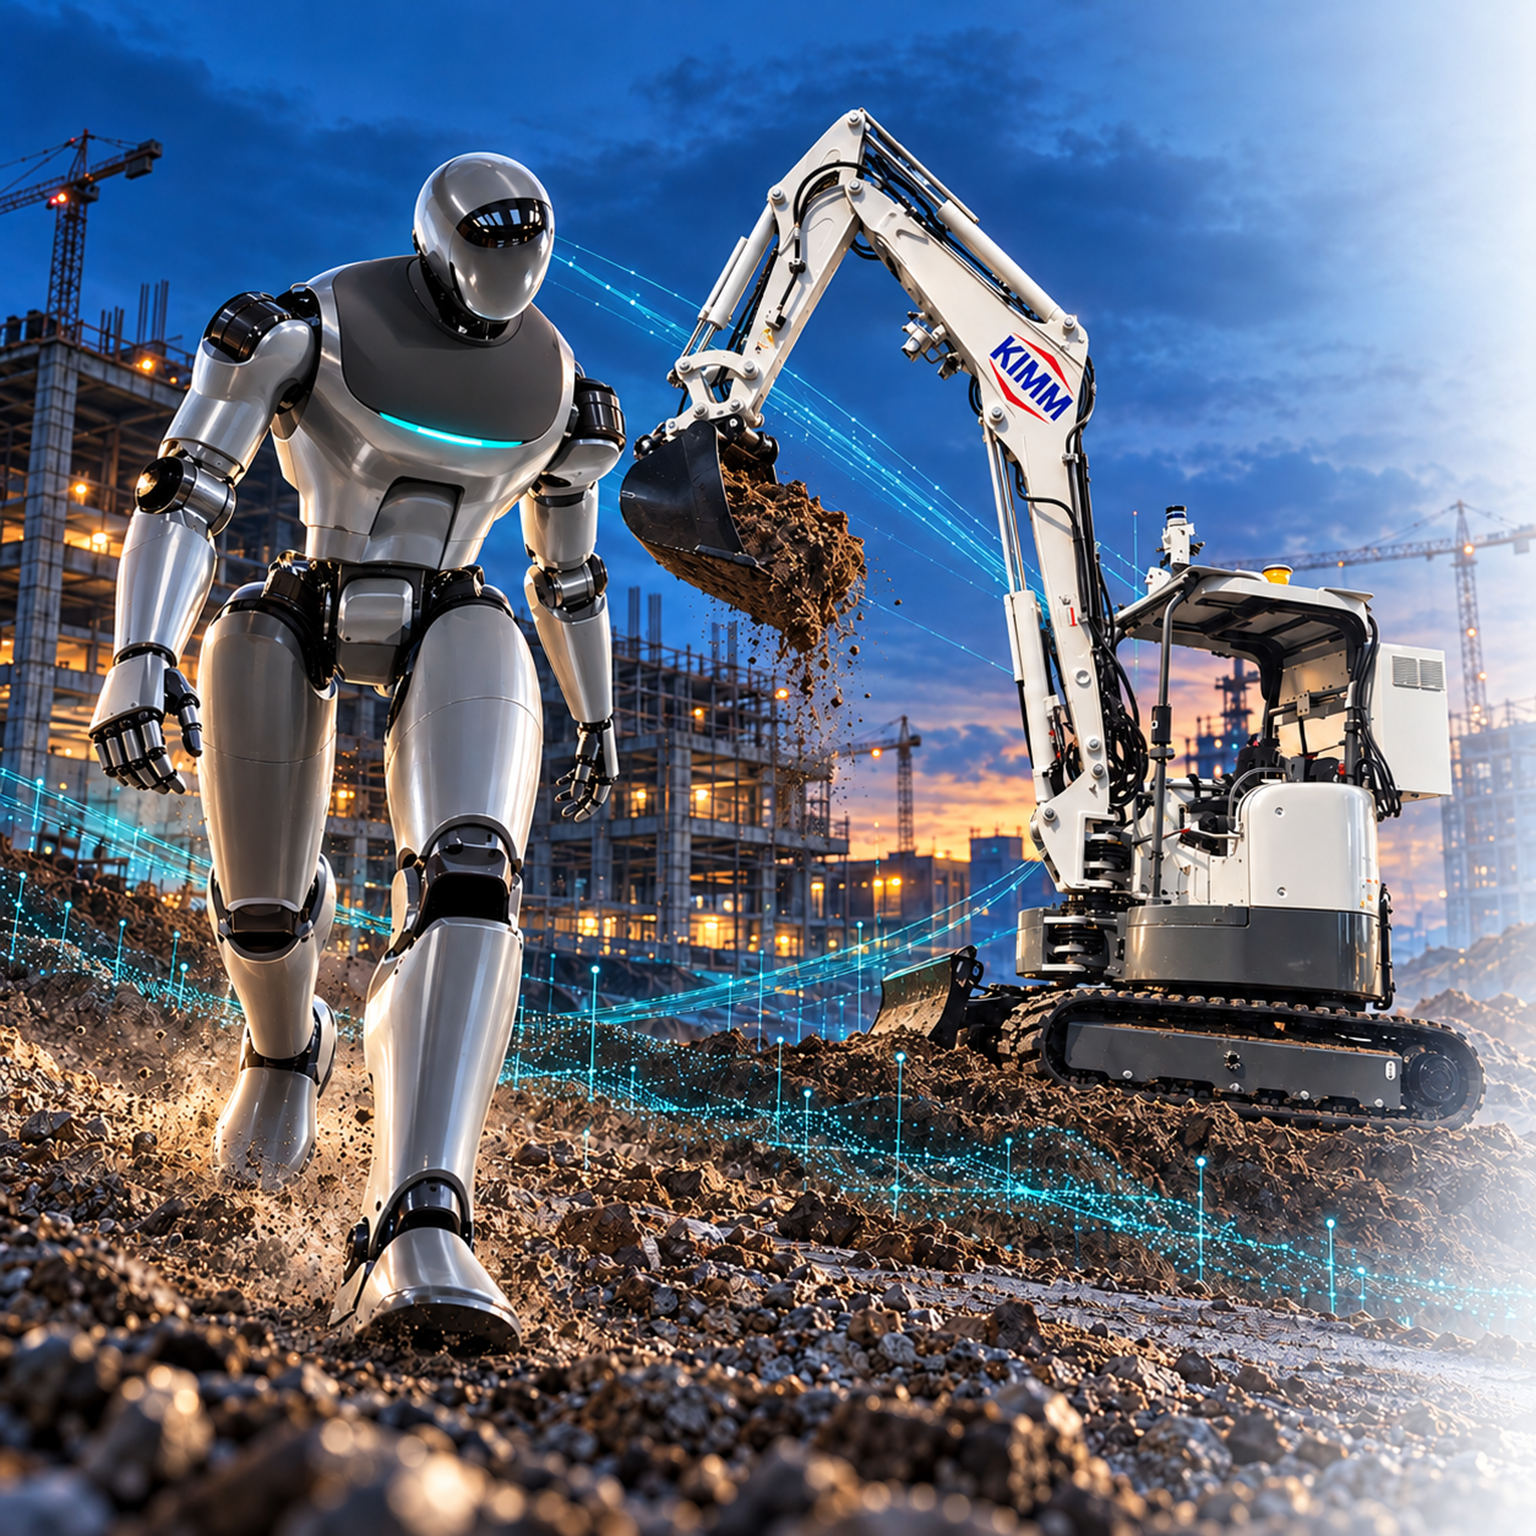
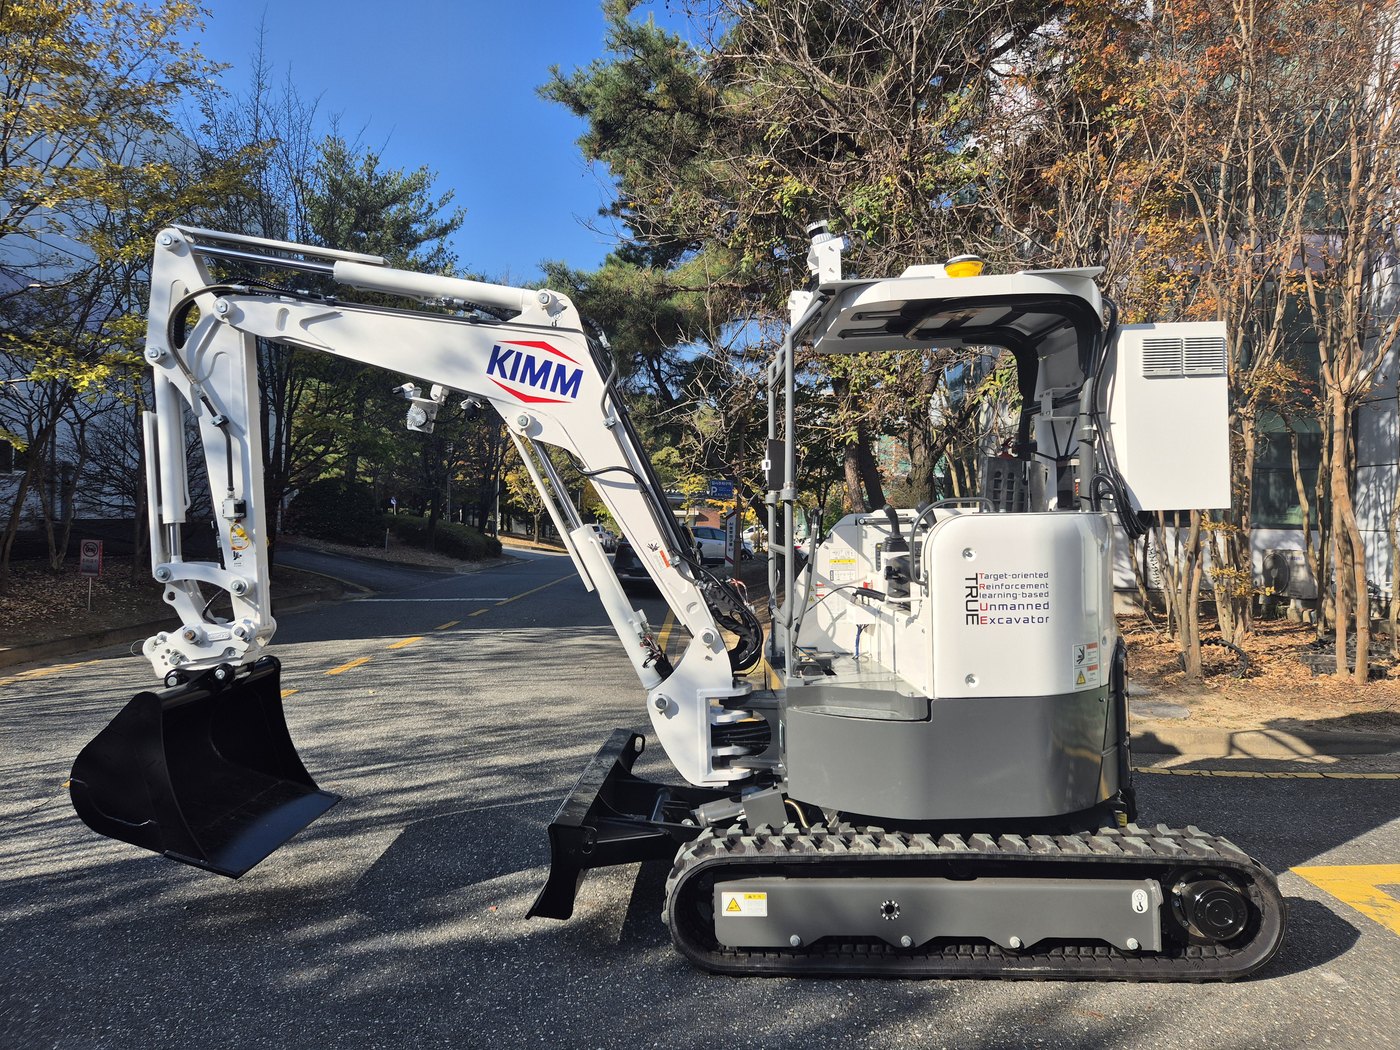
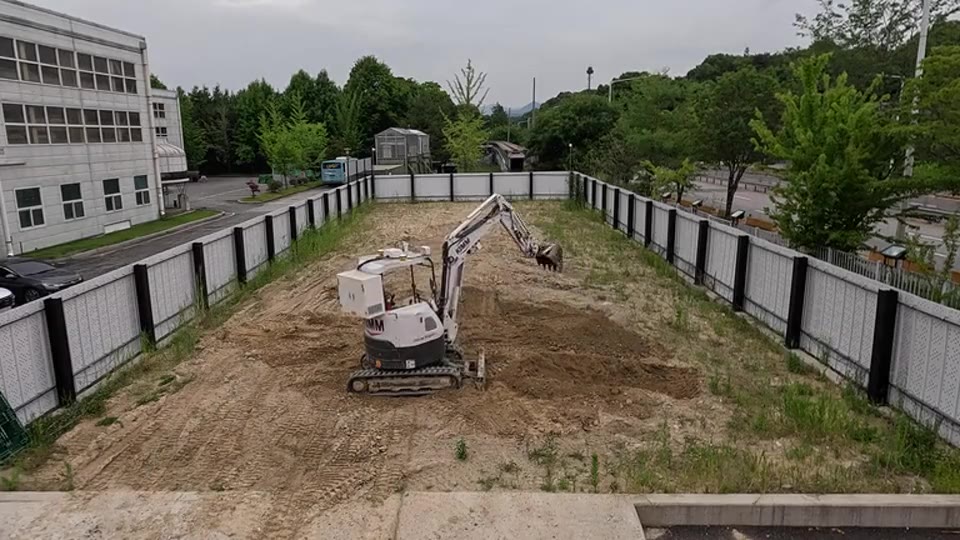
ConstructionAutonomous trench excavation
KIMM 3.5-ton autonomous excavator
Terrain grid → digging point
Target depth 0.60 mMeasured avg. 0.63 m
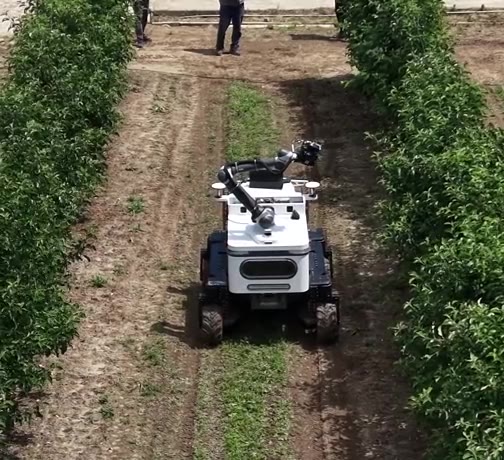
AgricultureOrchard pest scouting
Autonomous driving in an open orchard
Detecting pests among leaves
Scouting once done by eyeThe robot drivesand detects and logs on video
18
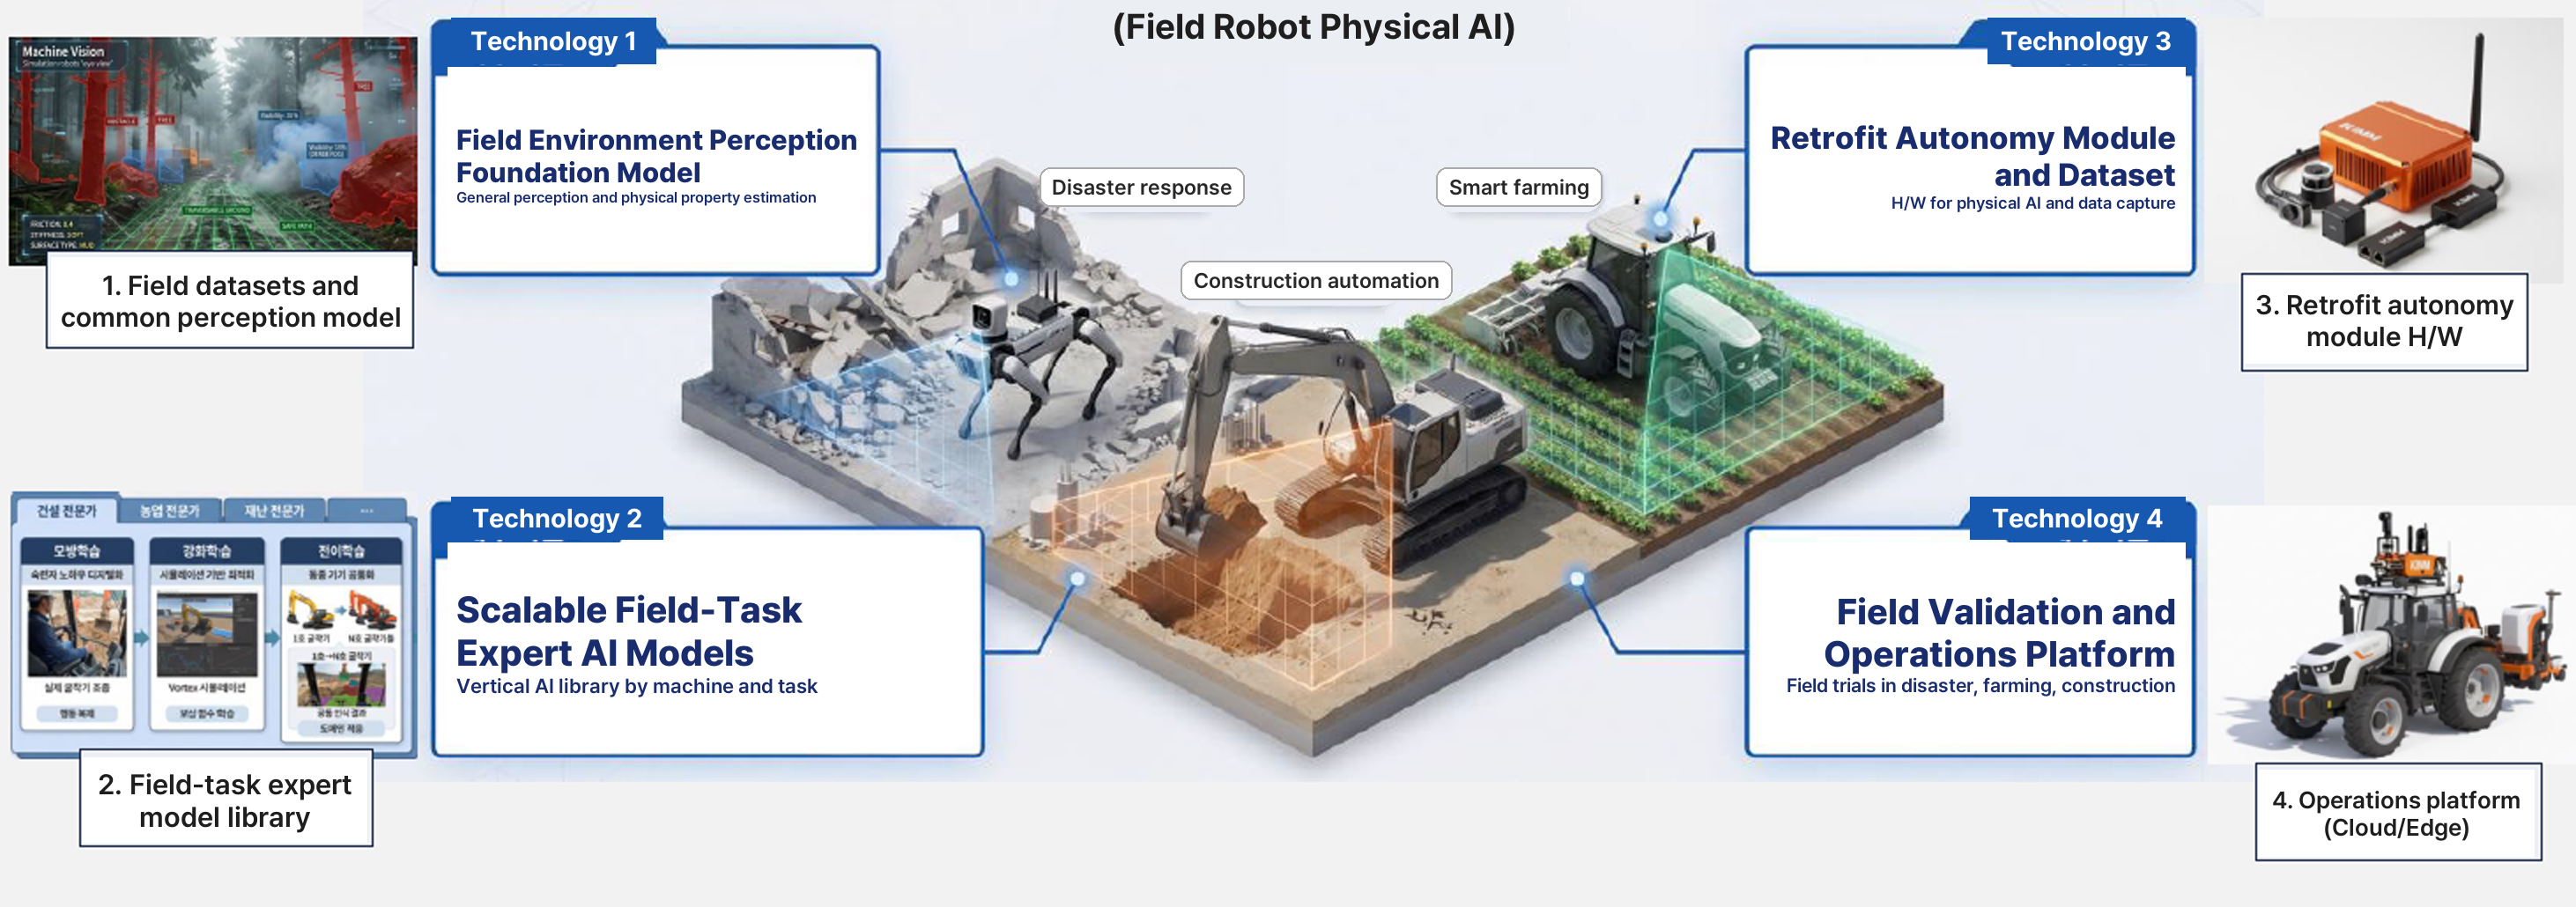
18. Field Robot Physical AI
One common perception model to automate construction, agriculture, and disaster equipment
AI field robots for labor shortages and hazardous environments
Disaster quadruped
Agriculture tractor
Agriculture orchard scout
Construction excavator
Construction material carrier
5 machine typesLevel 4autonomy
19
19. Medical Robots
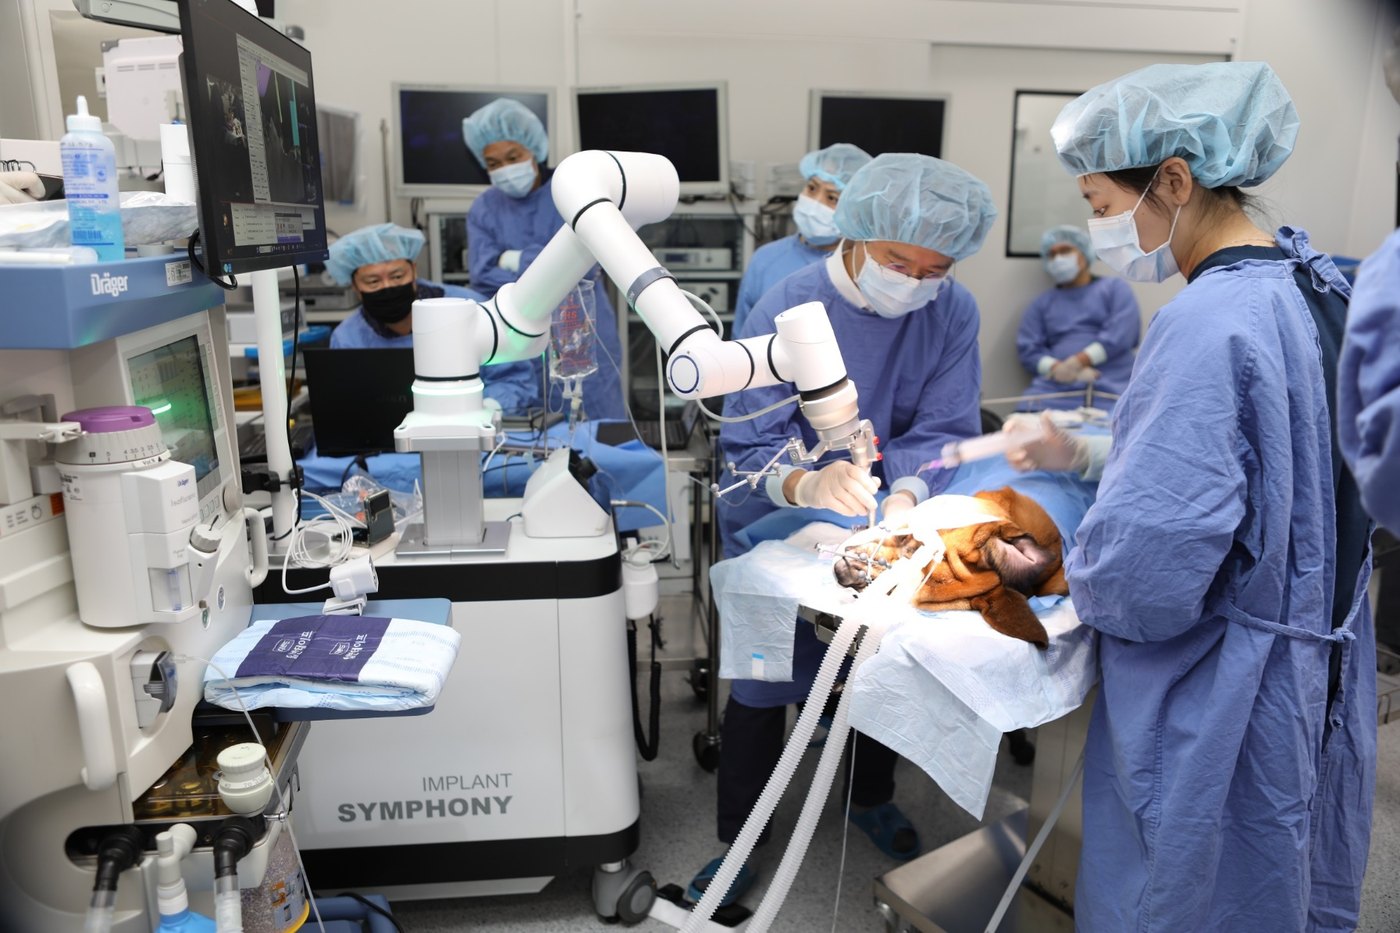
Expanding medical capability through precision manipulation and remote control
PrecisionMinimally invasive catheter robot
Catheter in a heart model
Steers the tip of a thin tube precisely, without tremor
RemoteRemote ultrasound, Ulleungdo–Daegu
Doctor · control
⇄295 kmRound trip ~40 ms
Robot · ultrasound
A remote robot follows the doctor's hand to acquire ultrasound images
20
20. Digital Twins
Linking real equipment and virtual twins in real time for learning and optimization
Real equipmentDigital twin
Autonomous tractor — field work monitored live in the twin
Digital twinReal machines
Autonomous machining cell — machine and robot motion synced with the twin
美 Digital Twin ConsortiumOfficial testbed
MANDATE-R2R Autonomous roll-to-roll battery manufacturing Real equipment and twin linked in real time; multiple AI agents optimize the process · registered 2025.12
21
21. The Physical AI Industrial Ecosystem
From R&D to field use, connection builds industrial competitiveness
AI and dataModels and field data
+
Core tech and partsActuators and robot hands
→
Integration
KAIROS
Integrating into field-ready robot systems
→
Testing and evaluation
Autonomous excavation test site
Verifying performance and safety in real conditions
→
Companies and industry
Orchard field pilot
Deployed and used at real work sites
KIMM develops core technology, integrates systems, and connects them to field validation
22
22. Physical AI and Energy
Energy powers robots, and robots work at energy sites
Energy
Power and charging — the basis for sustained work
Construction and inspection — hands for energy sites
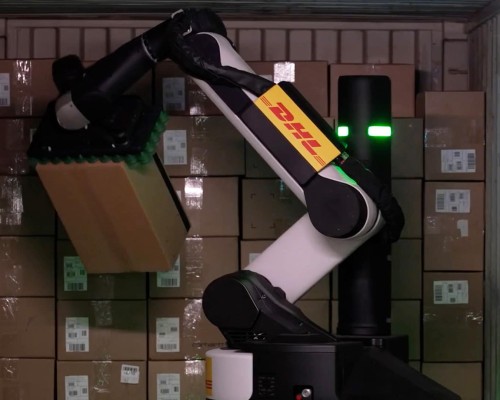
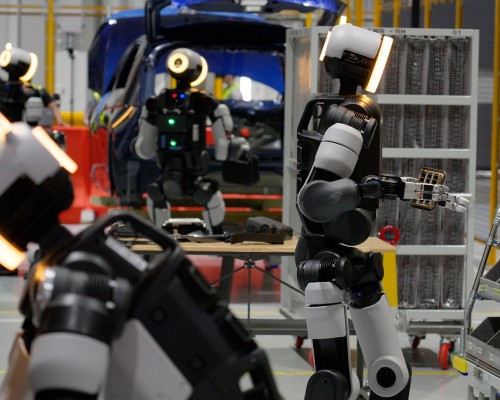
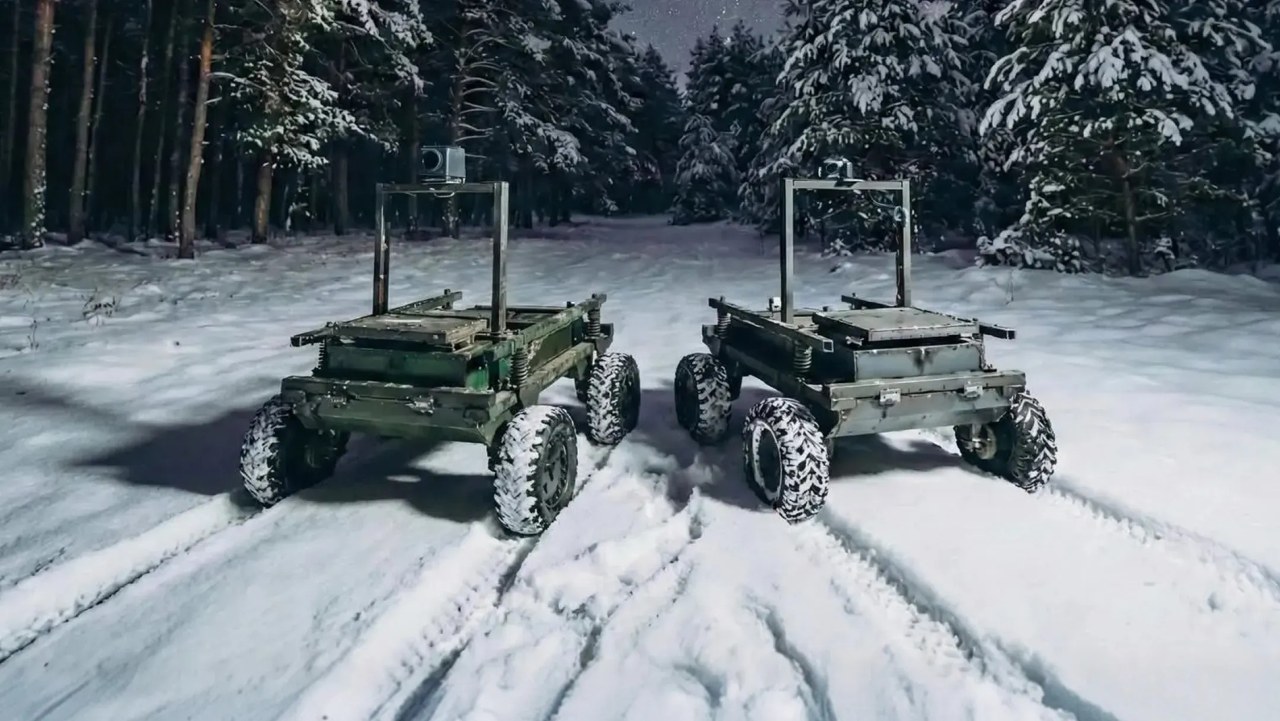
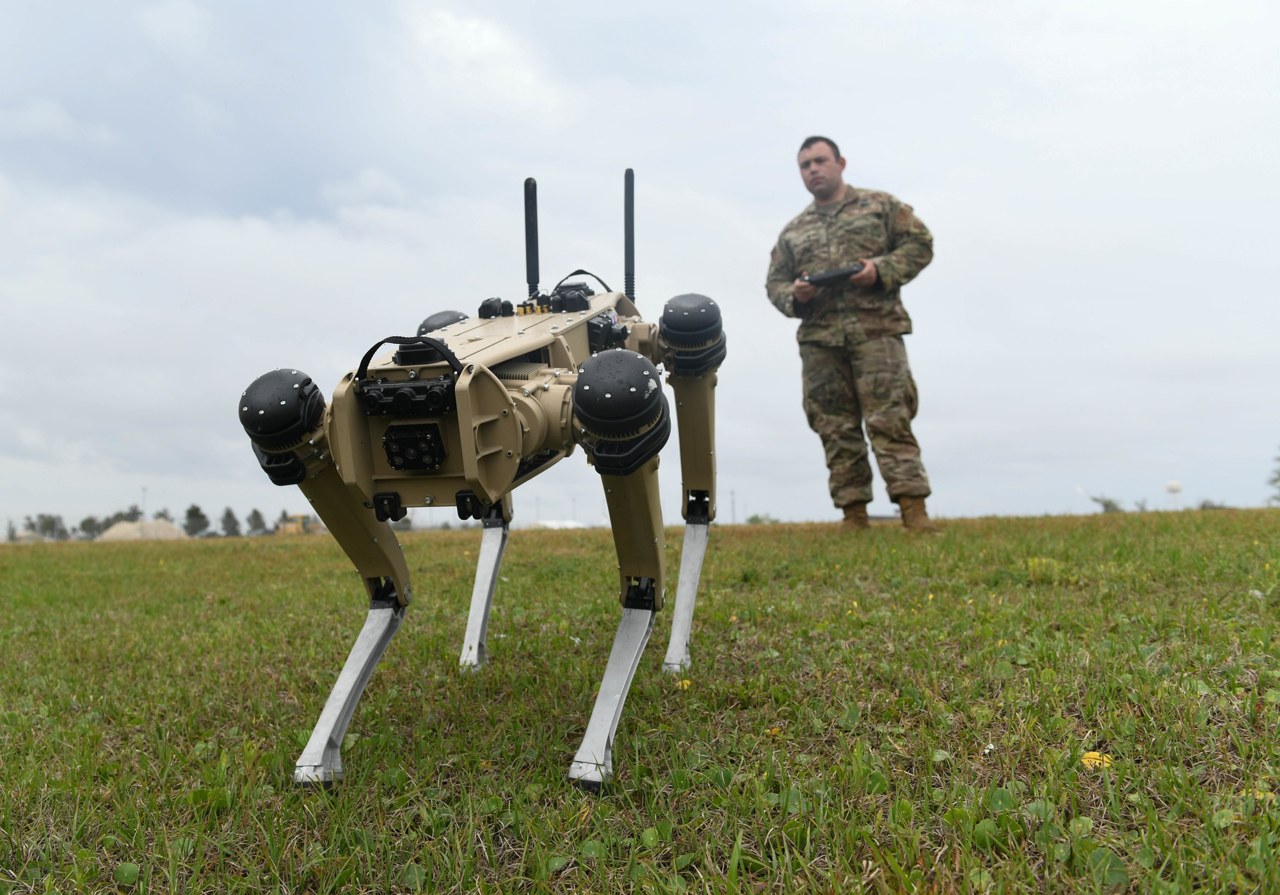
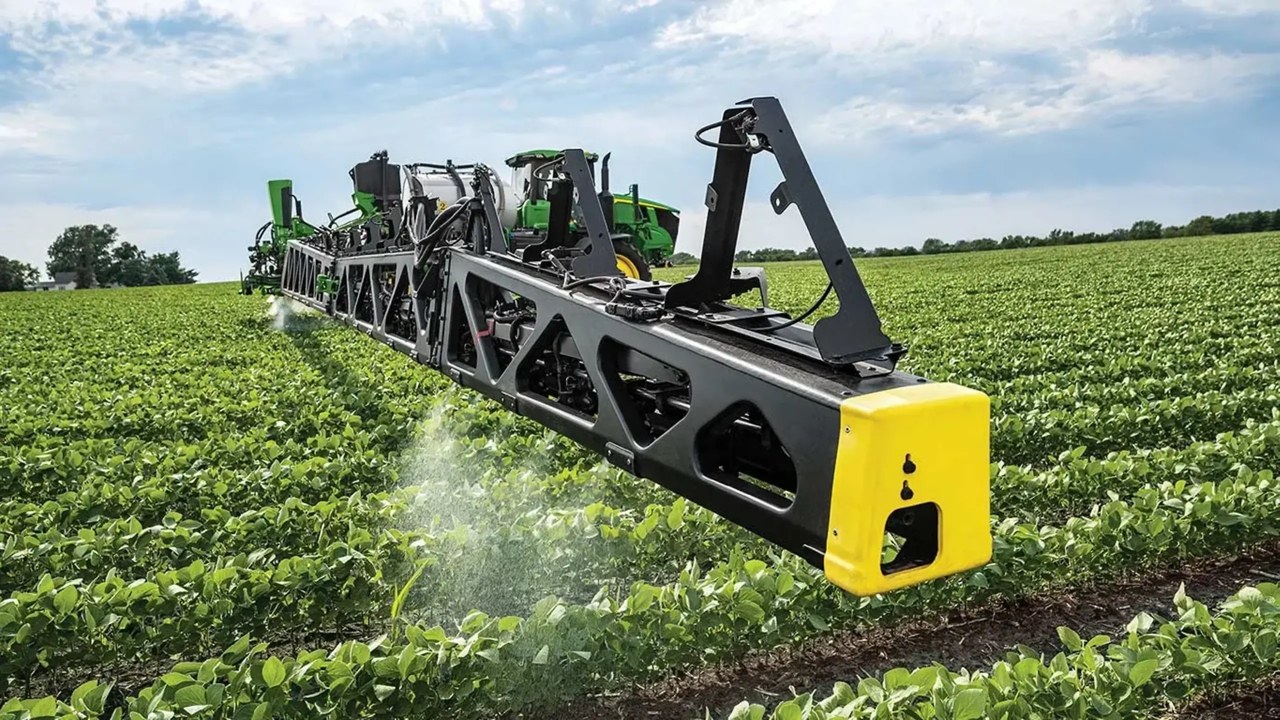
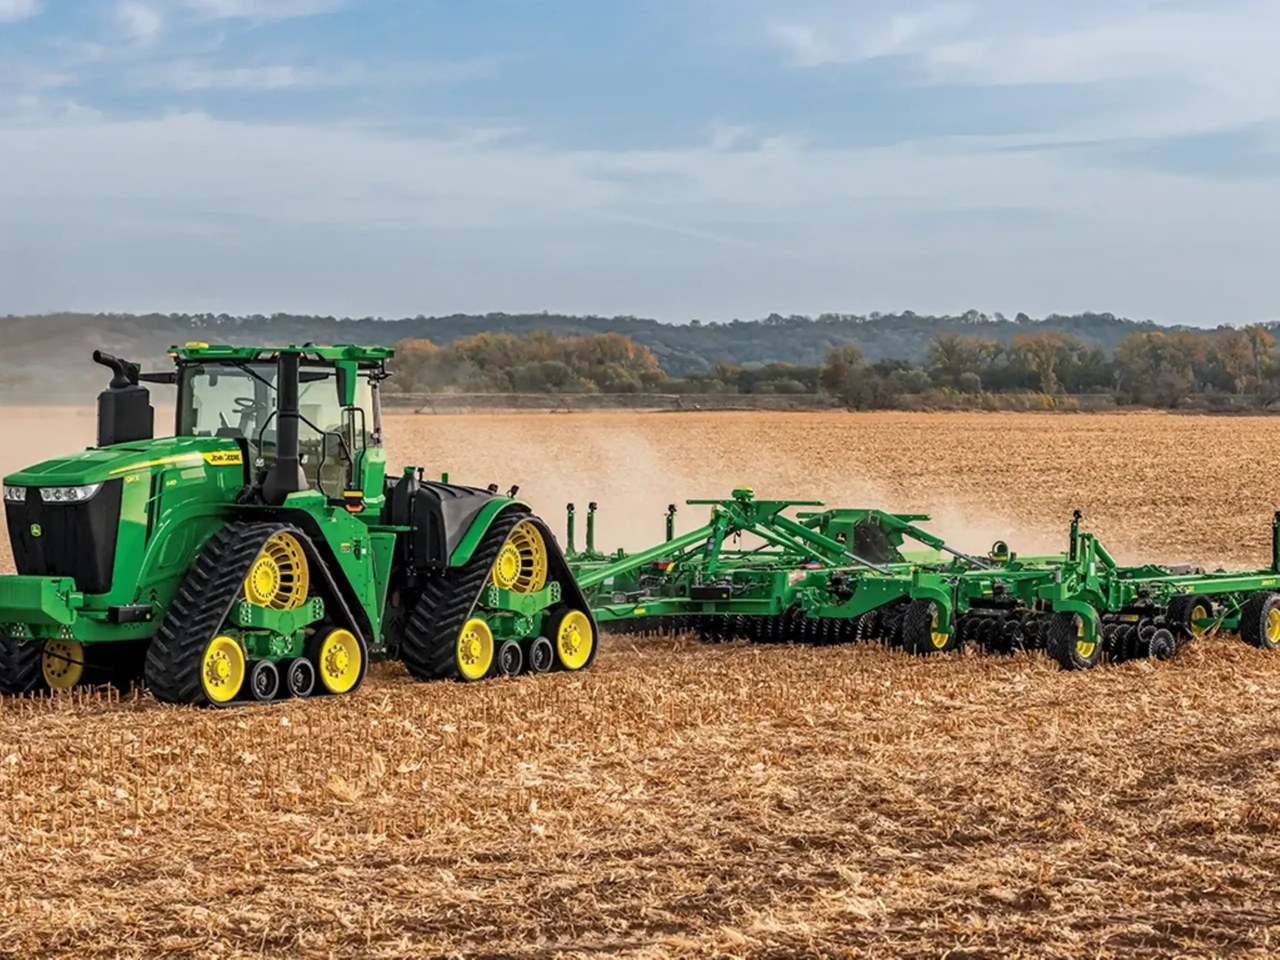
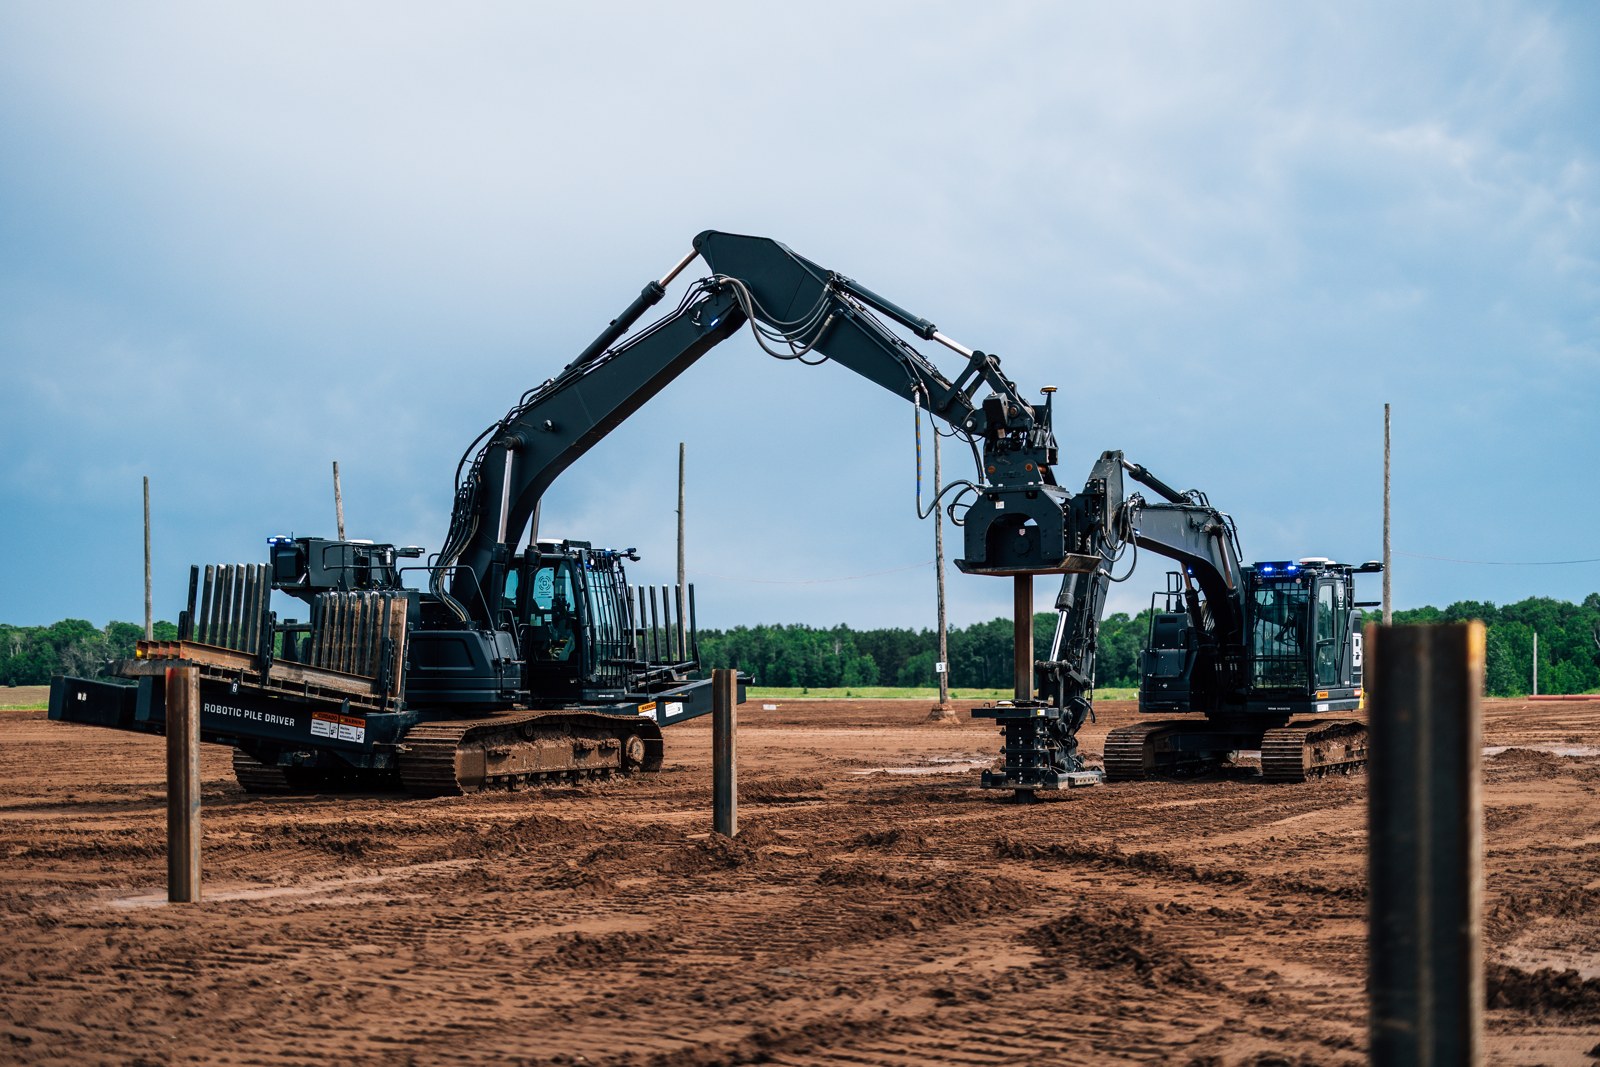
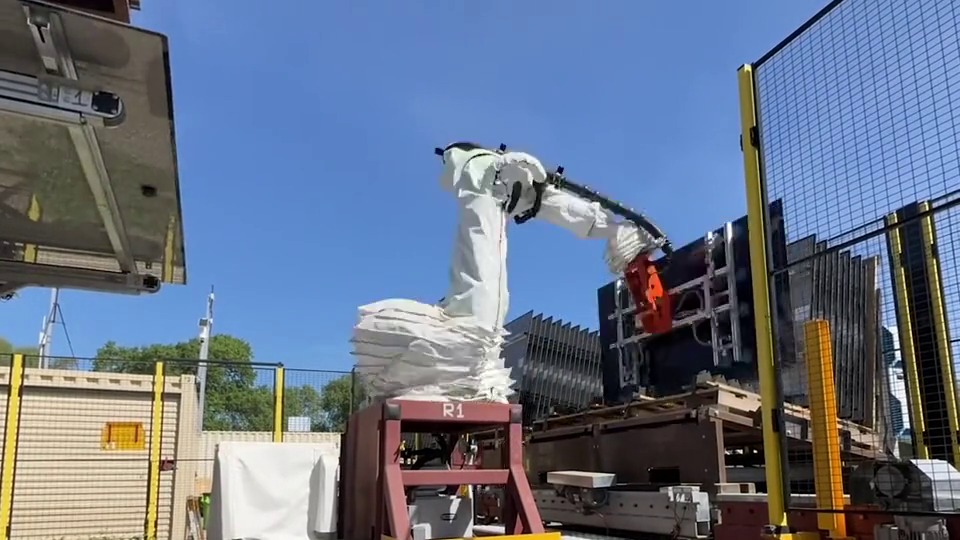 © Terabase Energy
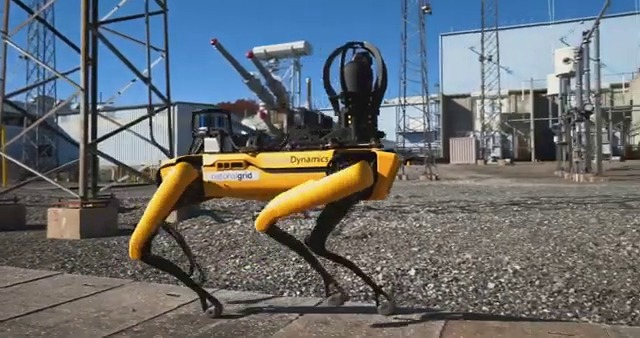 © Boston Dynamics